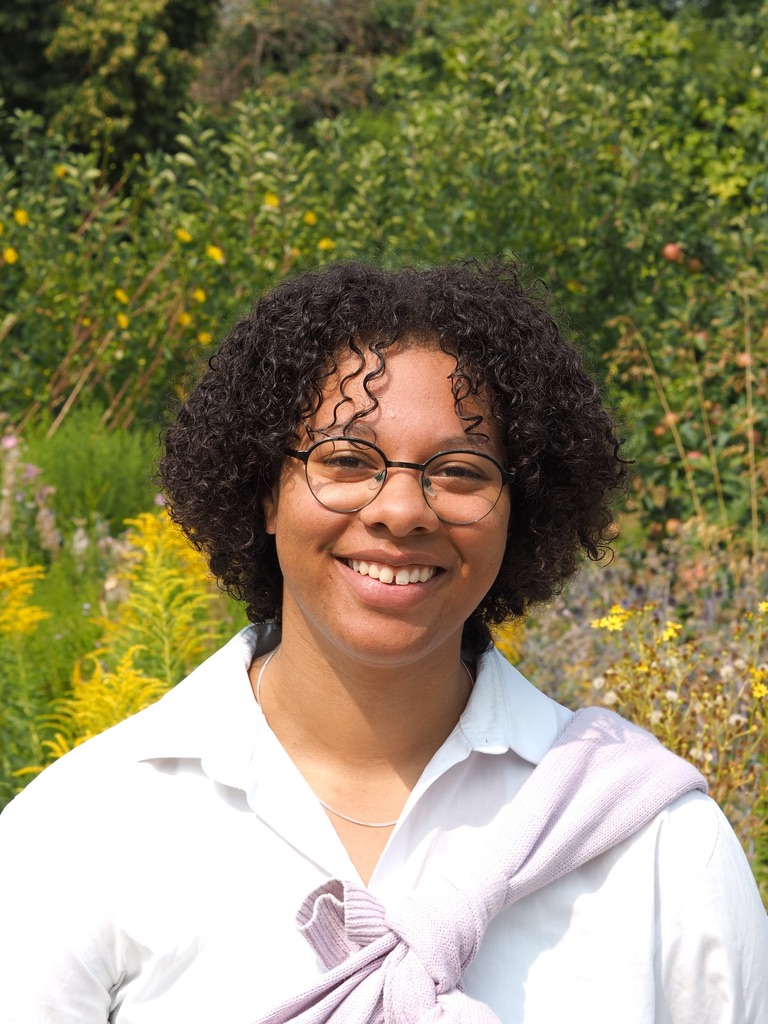
Akira Adeniran-Lowe
MSc. Graduate in Autonomous Systems
News
Pre-print released on arXiv (Under Review): PAGER: Partial-to-Global Alignment via Geometric and Relational Distillation. arXiv:2610.01589 • Project Page.
Graduated with an MSc. in Autonomous Systems (Hons.) from the Technical University of Denmark (DTU).
Completed external research stay at KTH Royal Institute of Technology in Stockholm, Sweden (Jan 2026 – Jun 2026).
Paper published in IEEE Access: "Concept Drift Under Harsh Constraints: A Review of Potential Strategies for IoT Systems". View on IEEE Xplore.
Admitted to DTU's competitive Honours Programme for the MSc. in Autonomous Systems.
Graduated with a BSc. in General Engineering (Cyber Systems) from DTU (10.2 GPA), concluding bachelor thesis on "Anti-Deepfake Methods for Multimodal Technologies".
Publications
Selected Research
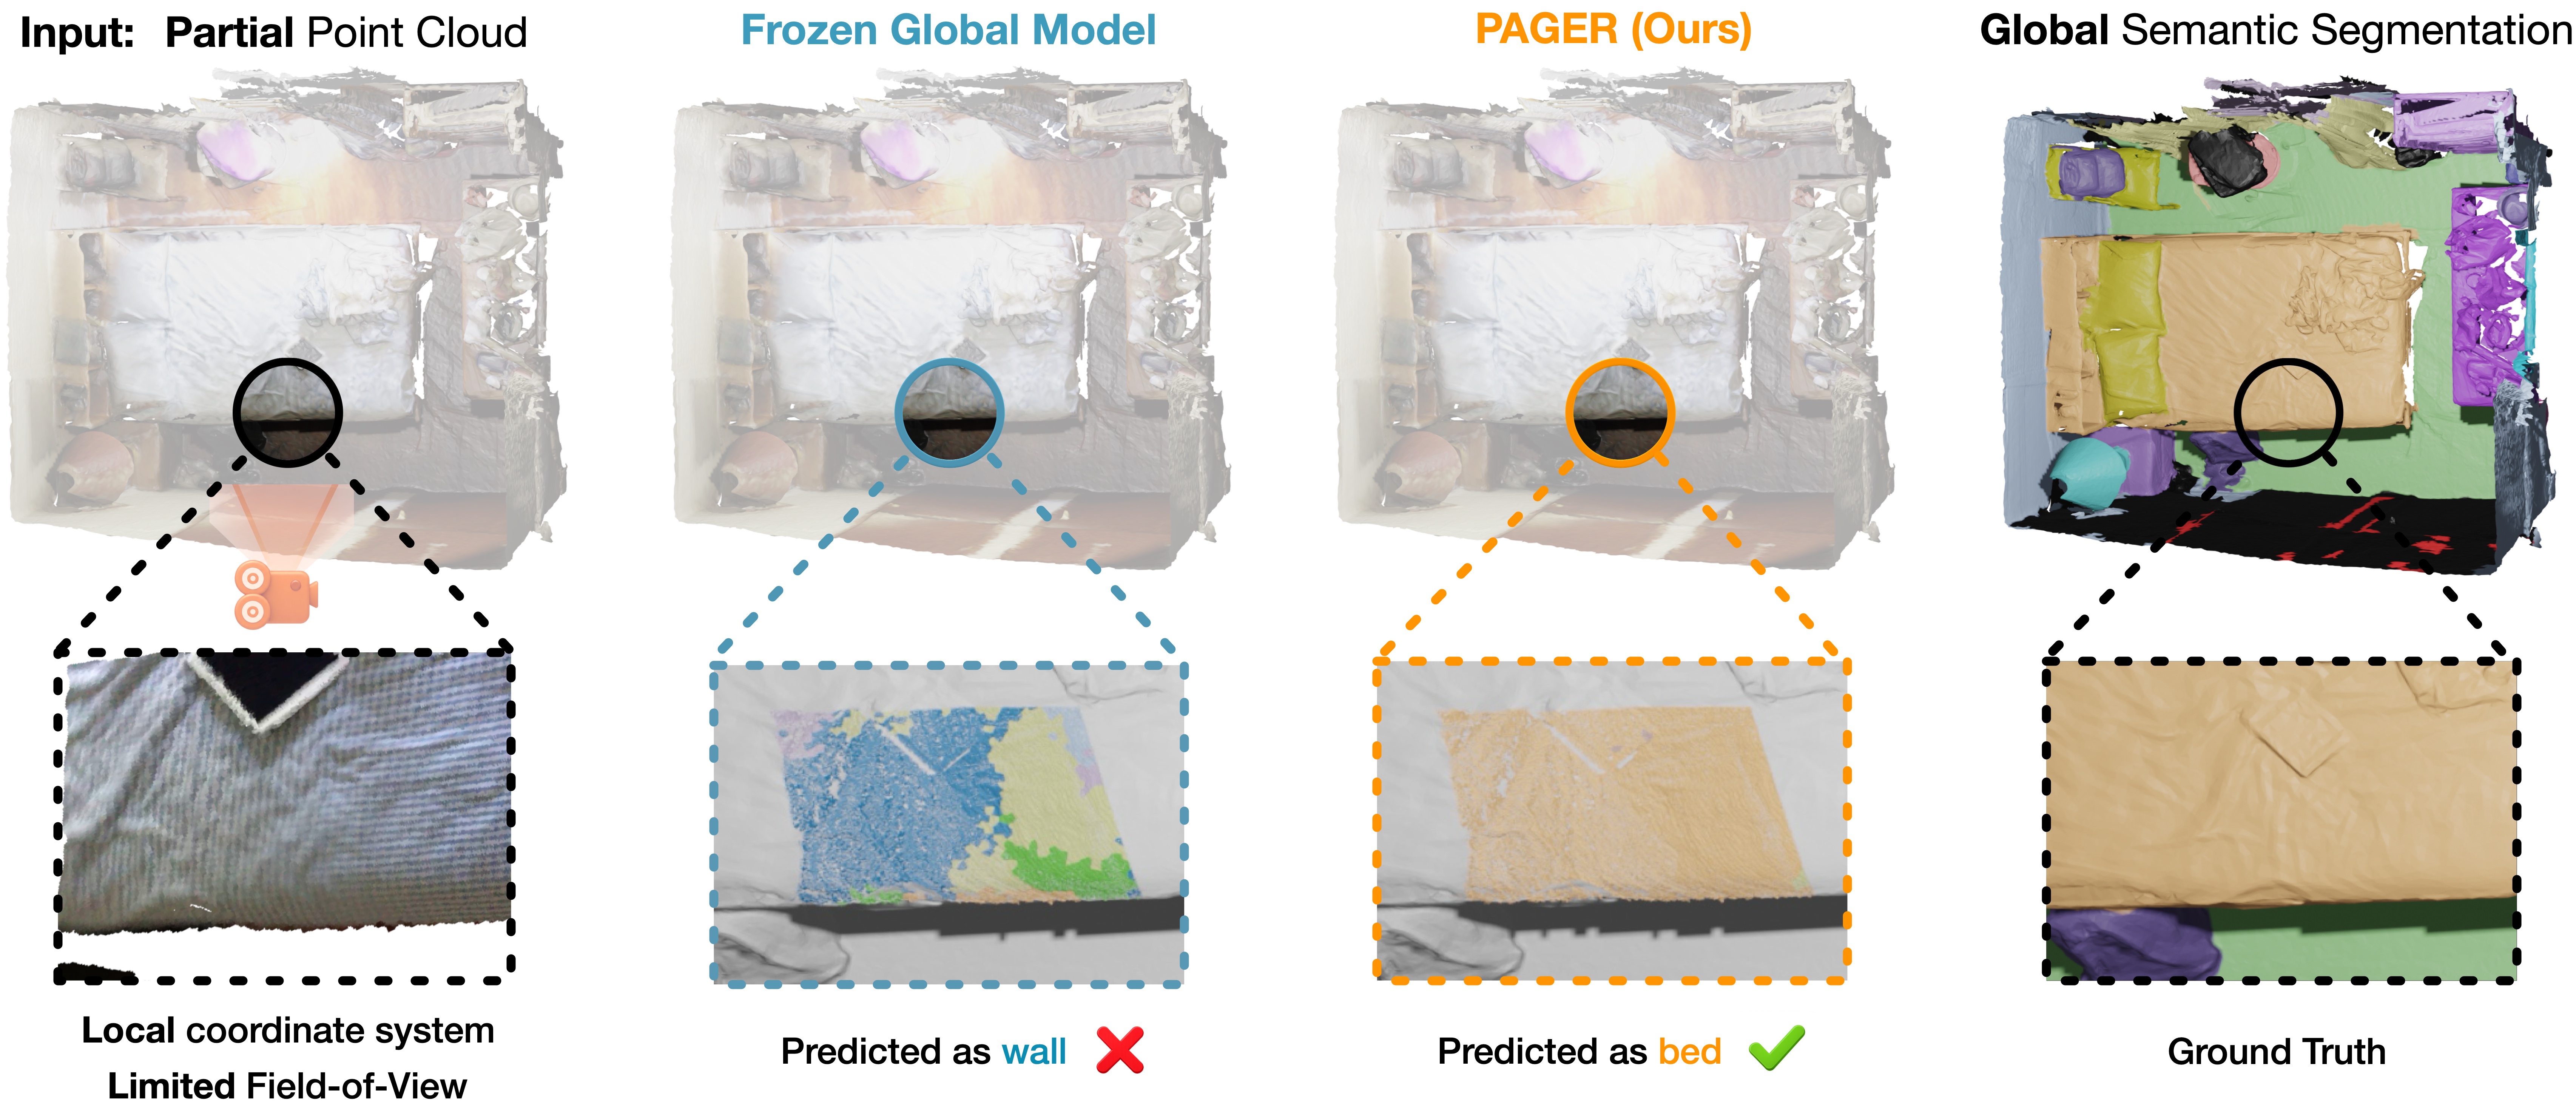
PAGER: Partial-to-Global Alignment via Geometric and Relational Distillation
Akira-Miranda Adeyomi Adeniran-Lowe, Binod Singh, Lars Arnold Dethlefsen, Lazaros Nalpantidis, Theodora Kontogianni
Technical University of Denmark & Pioneer Center for AI
A label-free adaptation framework that bridges the representation gap between globally trained 3D encoders and realistic, partial point clouds in camera coordinates using paired partial/global geometry without requiring annotations.
Concept Drift Under Harsh Constraints: A Review of Potential Strategies for IoT Systems
Ask Espensønn Øren, Nina Kuna Peuker, Akira Adeniran-Lowe, Sarah Ruepp, Martin Nordal Petersen
Explores algorithmic strategies for continuous concept drift detection in machine learning models deployed on resource-constrained microcontrollers and edge hardware, enabling adaptation without constant cloud dependence.

Education
MSc. in Autonomous Systems (Hons.)
Technical University of Denmark (DTU)
Specialization: 3D Computer Vision, Robust Perception, and Adaptive Autonomous Systems.
External Stay: KTH Royal Institute of Technology, Stockholm, Sweden (Jan 2026 – Jun 2026).
Thesis: "Aligned Feature Learning for Semantic Segmentation on Partial Point Clouds" (Advisors: Theodora Kontogianni & Lazaros Nalpantidis).
BSc. in General Engineering – Cyber Systems
Technical University of Denmark (DTU)
Curriculum: Embedded Systems, Software Engineering, Image Analysis (10.2 GPA).
Exchange: Nanyang Technological University (NTU), Singapore.
Thesis: "Anti-Deepfake Methods for Multimodal Technologies" (Advisor: Sneha Das).
Teaching Experience
Embedded Systems Programming
Teaching Assistant • BSc. Level
Technical University of Denmark
Design-Build 4: Autonomous Living Systems
Teaching Assistant • BSc. Level
Technical University of Denmark
Design-Build 1: Cell Growth Measurement
Teaching Assistant • BSc. Level
Technical University of Denmark
Get in Touch
I'm always open to research collaborations, thesis inquiries, and technical discussions.
Feel free to reach out via email or connect on LinkedIn. Based in Copenhagen, Denmark.